2025–Ongoing
DITTO
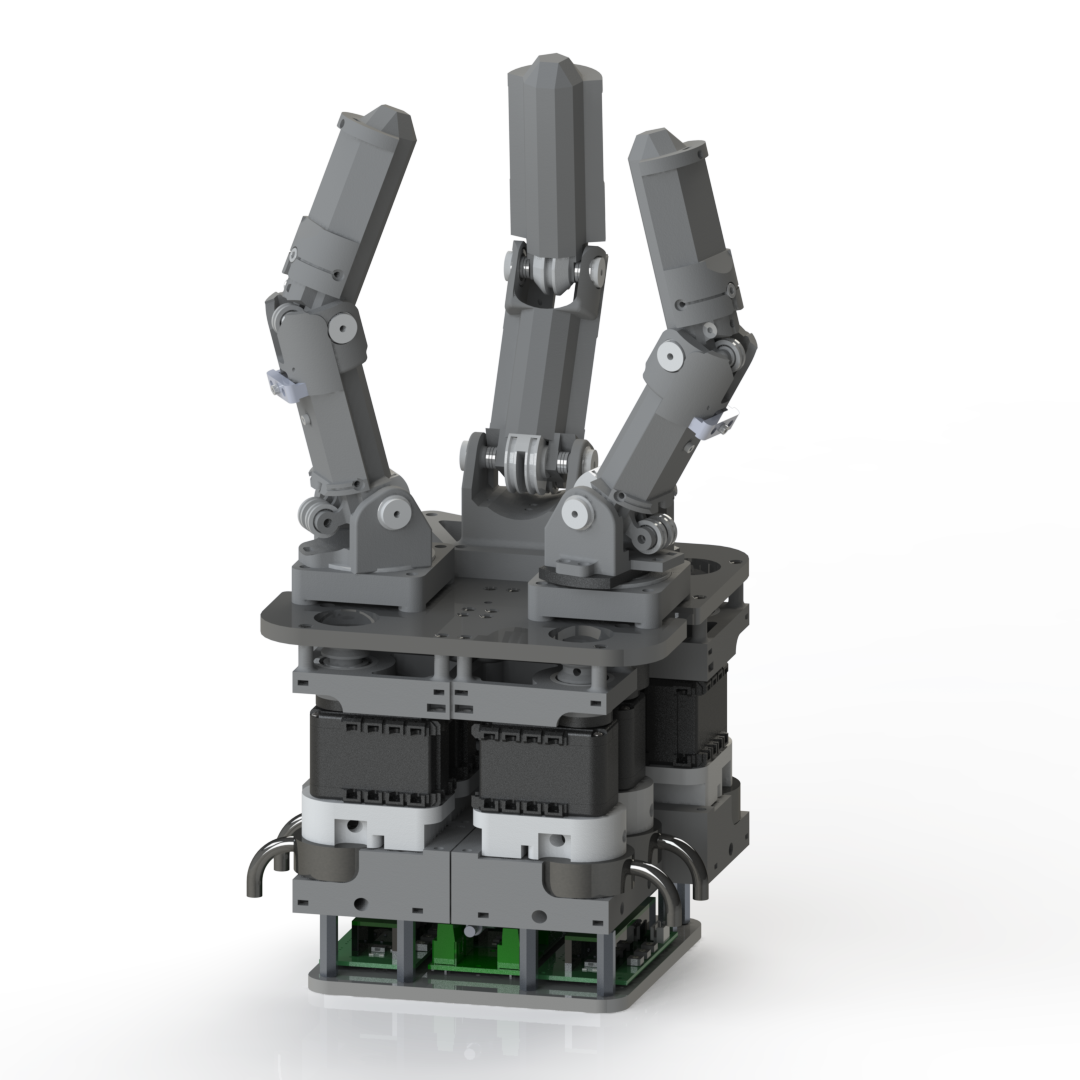
Co-designed dexterous hand and kinematically equivalent motorized exoskeleton for both handheld data collection and bilateral teleoperation with joint-level force feedback.
Home / Research
Hardware and controls research in dexterous manipulation and assistive robotics at ROAM Lab.
2025–Ongoing
Co-designed dexterous hand and kinematically equivalent motorized exoskeleton for both handheld data collection and bilateral teleoperation with joint-level force feedback.
2024–2025
Robot hand with 6-axis F/T sensorized fingertips and novel kinematics validated via RL policies.
Mechanical design and kinematic validation via reinforcement learning.
2022–2023
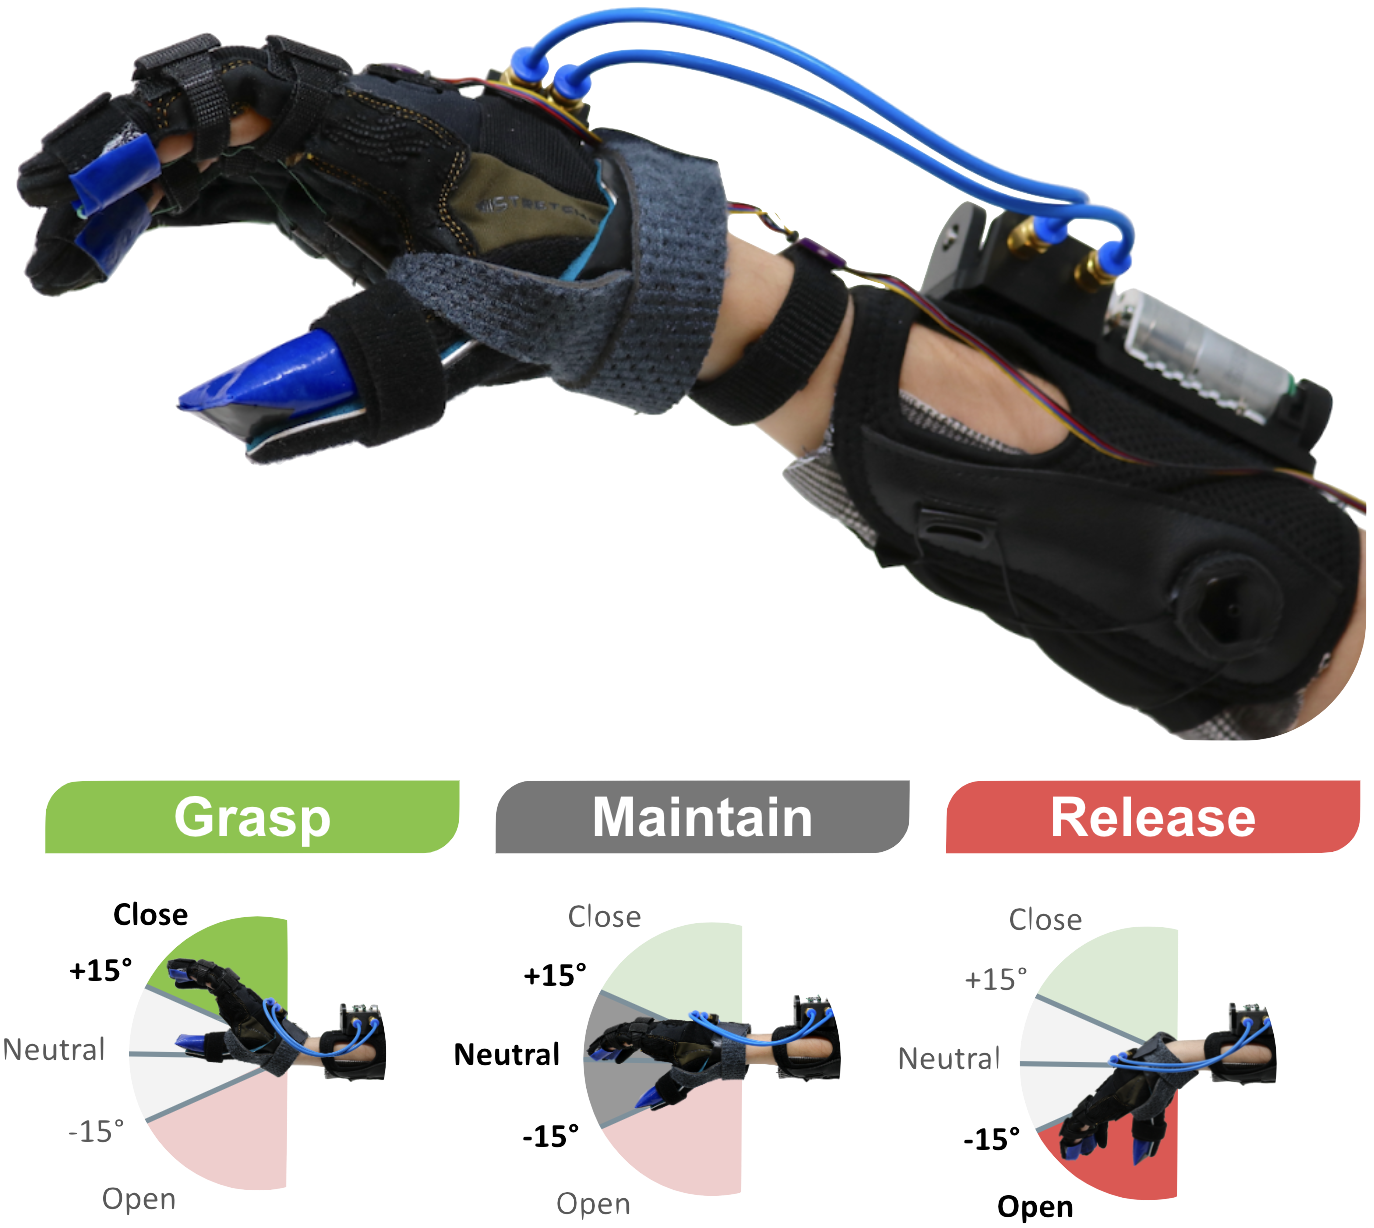
Creating a wearable robot to assist in grasping for individuals with Spinal Cord Injuries.
A study on tenodesis-based user control for grasping force modulation, promoting the development of intuitive assistive devices.
2023
Designing and building a robot hand to explore proprioception in dexterous robot manipulation.
Mechanical design and firmware implementation for torque control of a tendon-driven robot hand.