MyHand-SCI
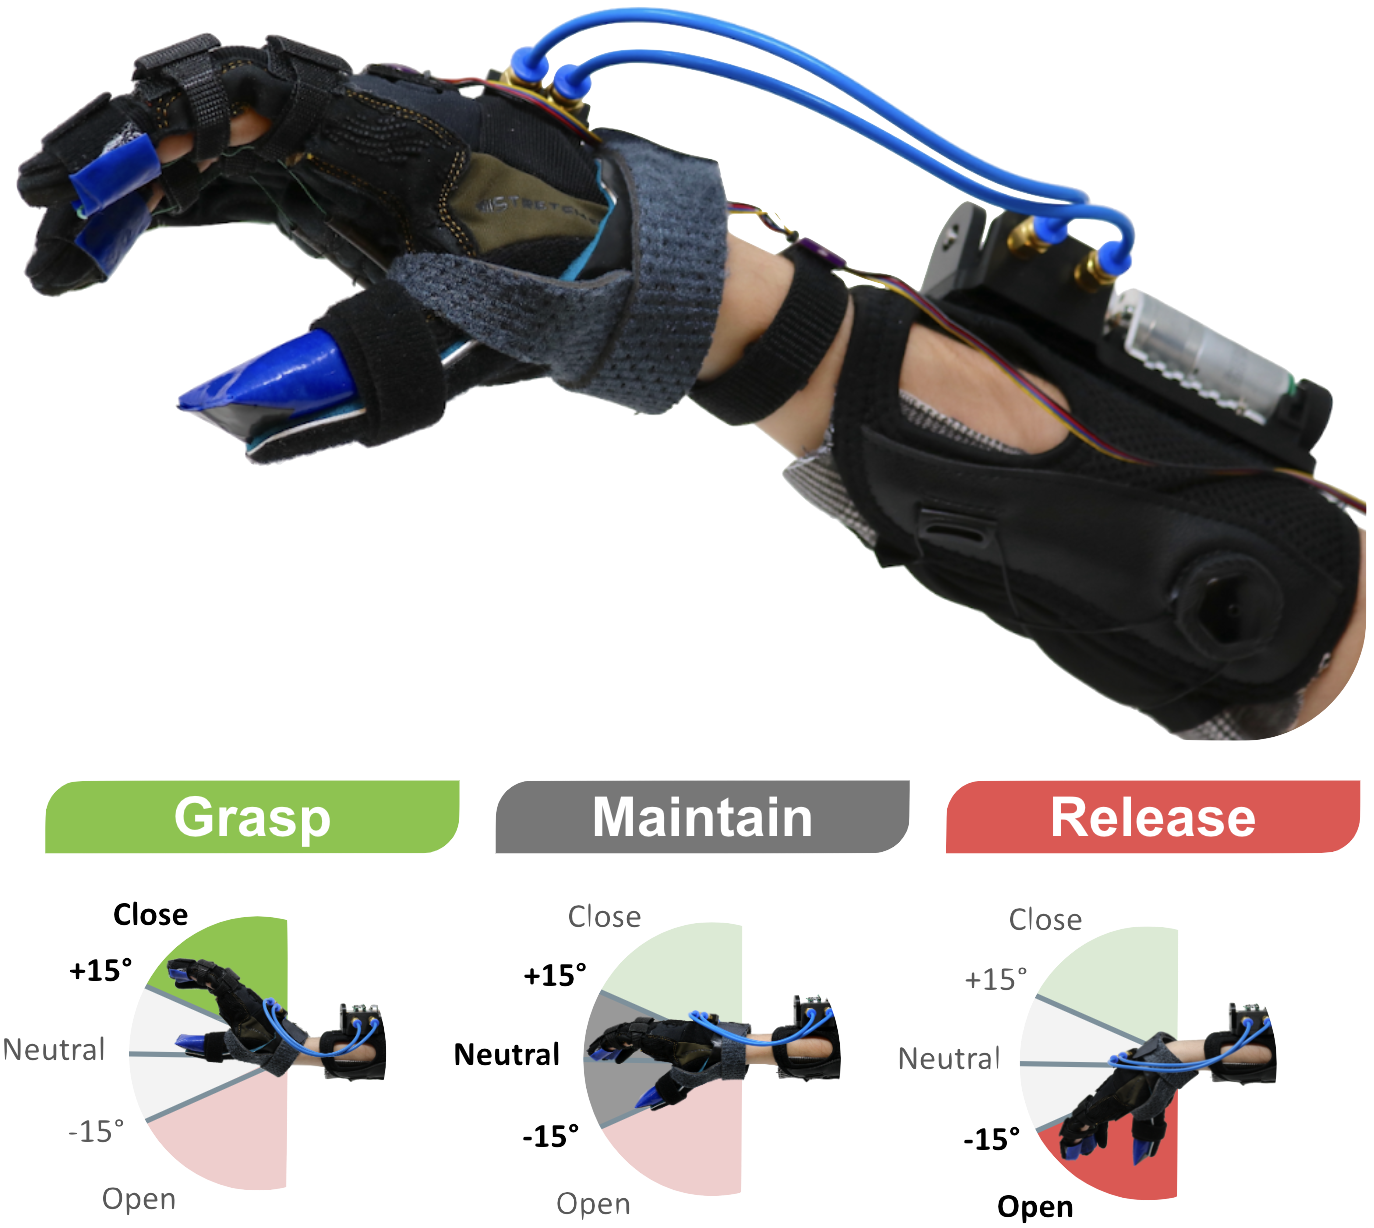
A wearable robot that provides active grasping assistance for individuals with Spinal Cord Injuries (SCI).
Description:
For the MyHand-SCI we adopted a philosophy of augmenting, rather than overshadowing, an individual’s residual motor skills. The MyHand-SCI aims to leverage the tenodesis grasp, a compensatory grasping pattern utilized by individuals with C5–C6 injuries, as a user control modality.
We believe this can make the device more intuitive for this population, give the user more agency and direct feedback, and thus encourage user adoption.
Publications
Journal paper, T-MRB [Nov, 2024]
Workshop abstract, IROS 2023!
- I gave a spotlight presentation and poster presentation at the Assistive Robots for Citizens Workshop at IROS 2023.